


Flix (flight + X) — open source ESP32-based quadcopter made from scratch.
| Version 1.1 (3D-printed frame) | Version 0 |
 |
 |
- Dedicated for education and research.
- Made from general-purpose components.
- Simple and clean source code in Arduino (<2k lines firmware).
- Communication using MAVLink protocol over Wi-Fi or ESP-NOW.
- Control with USB gamepad, remote control or smartphone.
- Wireless command line interface and analyzing.
- Precise simulation with Gazebo.
- Python library for scripting and automatic flights.
- Textbook on flight control theory and practice (in development).
- Position control (planned).
See detailed demo video: https://youtu.be/hT46CZ1CgC4.
Version 0 demo video: https://youtu.be/8GzzIQ3C6DQ.
Usage in education (RoboCamp 2025): https://youtu.be/Wd3yaorjTx0.
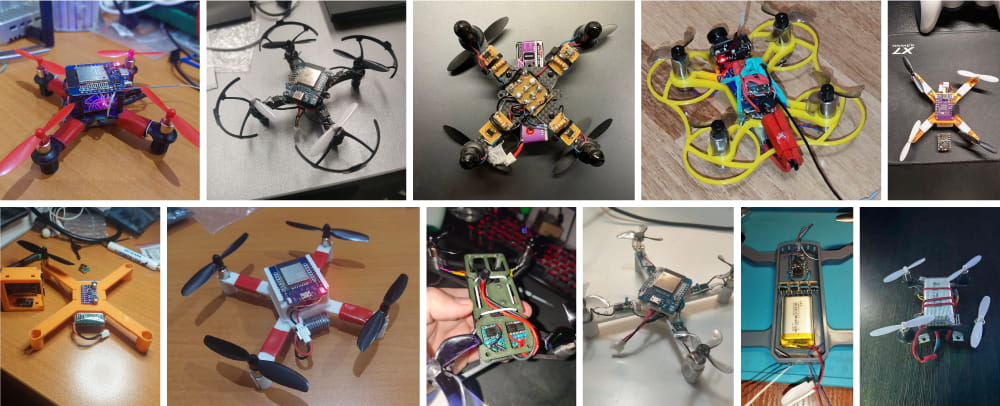
See the user builds gallery:
The official PCB (Flix2) is in development now. Follow the project's channel to track the progress.
Outdoor flights demo video of the current prototype:
The position control feature is in development. RoboCamp 2026 demo (using an overhead camera, sources):
The simulator is implemented using Gazebo and runs the original Arduino code:

Additional articles:
| Type | Part | Image | Quantity |
|---|---|---|---|
| Microcontroller board | ESP32 Mini. ESP32-S3/ESP32-C3 boards are also supported. |
 |
1 |
| IMU (and barometer¹) board | GY‑91, MPU-9265 (or other MPU‑9250/MPU‑6500 board) ICM20948V2 (ICM‑20948) GY-521 (MPU-6050) |
   |
1 |
| Boost converter (optional, for more stable power supply) | 5V output |  |
1 |
| Motor | 8520 3.7V brushed motor. Motor with exact 3.7V voltage is needed, not ranged working voltage (3.7V — 6V). Make sure the motor shaft diameter and propeller hole diameter match! |
 |
4 |
| Propeller | 55 mm or 65 mm |  |
4 |
| MOSFET (transistor) |