



Newton is a GPU-accelerated physics simulation engine built upon NVIDIA Warp, specifically targeting roboticists and simulation researchers.
Newton extends and generalizes Warp's (deprecated) warp.sim module, and integrates
MuJoCo Warp as its primary backend. Newton emphasizes GPU-based computation, OpenUSD support, differentiability, and user-defined extensibility, facilitating rapid iteration and scalable robotics simulation.
Newton is a Linux Foundation project that is community-built and maintained. Code is licensed under Apache-2.0. Documentation is licensed under CC-BY-4.0. Additional and third-party license texts are available in newton/licenses.
Newton was initiated by Disney Research, Google DeepMind, and NVIDIA.
- Python 3.10+ (3.10 support is deprecated; removal planned for Newton 1.9; use 3.11+)
- OS: Linux (x86-64, aarch64), Windows (x86-64), or macOS (CPU only)
- GPU: Fresh installs currently select Warp 1.18, which requires an NVIDIA Turing GPU (compute capability 7.5+) and driver R580+ for CUDA acceleration.
On an R545–R579 driver or an older supported GPU, install with
warp-lang==1.17.0(see the installation guide). No local CUDA Toolkit is required; macOS runs on CPU.
For detailed system requirements, see the installation guide. For tested configurations and Newton's versioning and deprecation policies, see the compatibility guide.
pip install "newton[examples]"
python -m newton.examples
To install from source with uv, see the installation guide.
Explore community solvers, integrations, and applications through the newton-physics topic on GitHub.
To share your own project, add the newton-physics topic to your public repository's About section. See GitHub's guide to repository topics for instructions.
Projects opt in by adding the topic; inclusion does not imply endorsement or support by the Newton maintainers. External solvers and extensions are maintained separately from Newton. Check each project's documentation for maturity, compatibility, and support.
Before running the examples below, install Newton with the examples extra:
pip install "newton[examples]"If you run the examples from a source checkout with uv, use
uv run --extra examples -m newton.examples <example_name> instead of the
python -m newton.examples <example_name> commands below.
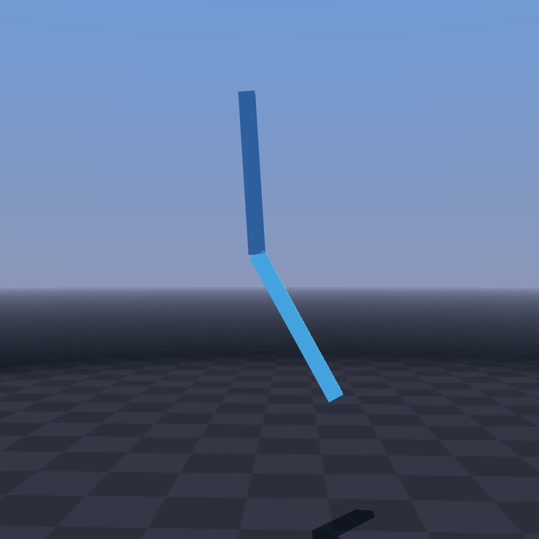
|
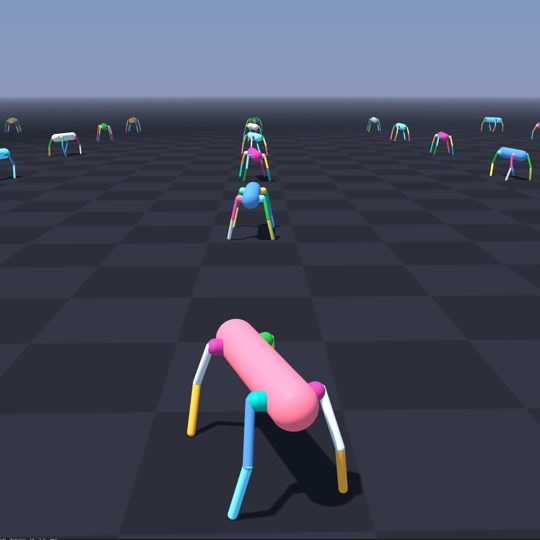
|
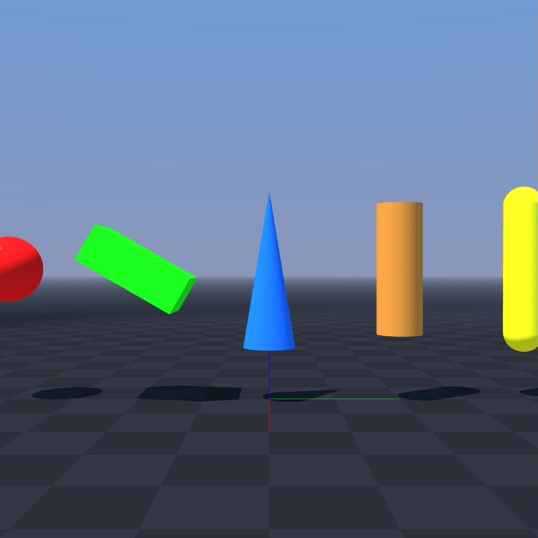
|
python -m newton.examples basic_pendulum
|
python -m newton.examples basic_urdf
|
python -m newton.examples basic_viewer
|
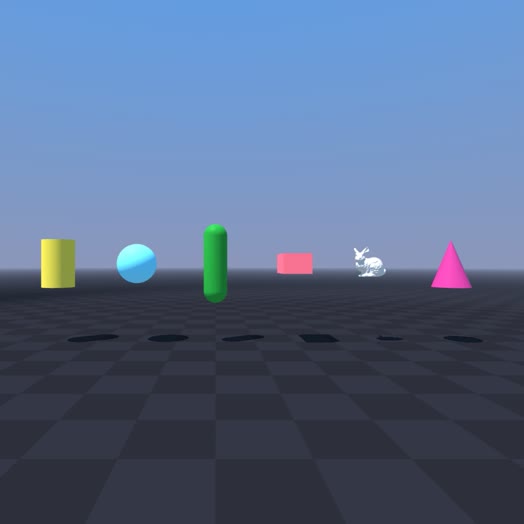
|
|
|
python -m newton.examples basic_shapes
|
python -m newton.examples basic_joints
|
python -m newton.examples basic_conveyor
|
|
|
|
python -m newton.examples basic_heightfield
|
python -m newton.examples recording
|
python -m newton.examples replay_viewer
|
|
|
|
python -m newton.examples basic_plotting
|
python -m newton.examples basic_dzhanibekov
|
python -m newton.examples basic_conveyor_forces
|
|
||
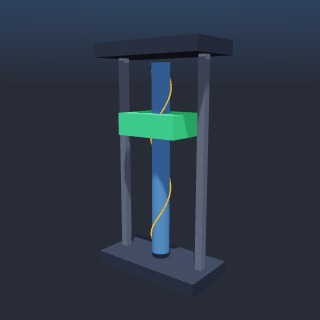
python -m newton.examples basic_mimic_joint
|
||
|
|
|
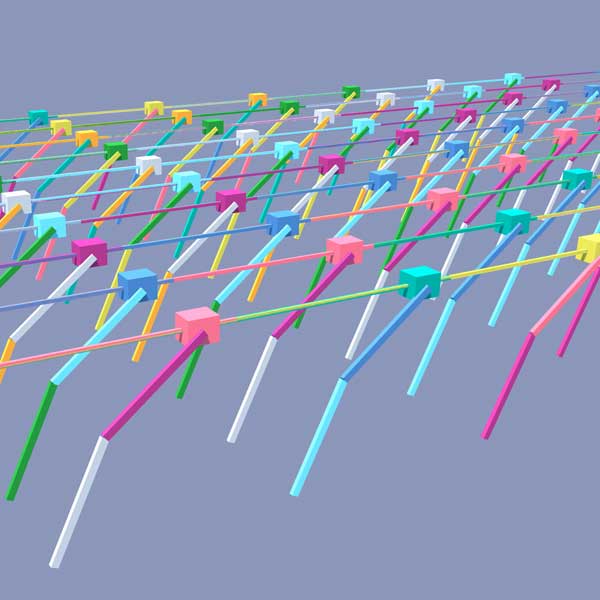
python -m newton.examples robot_cartpole
|
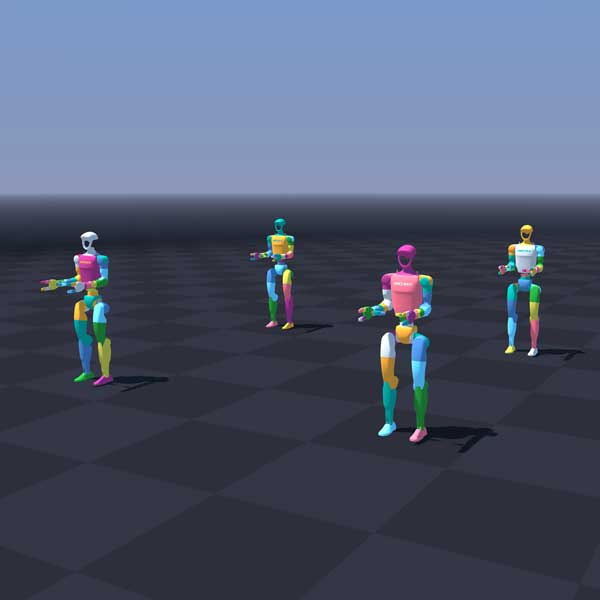
python -m newton.examples robot_g1
|
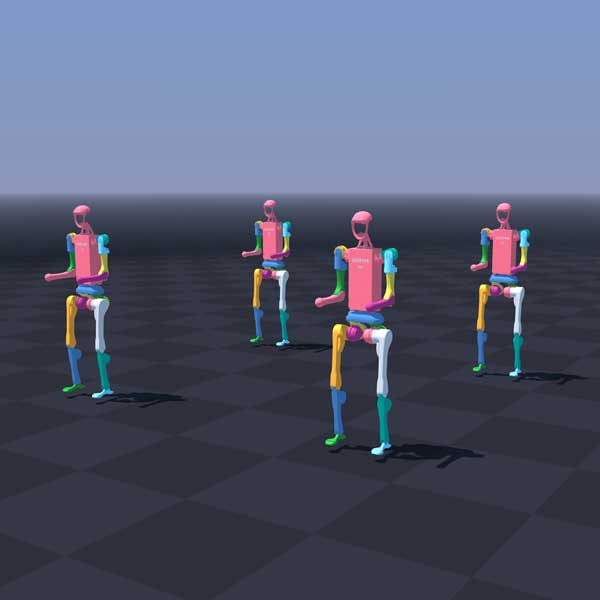
python -m newton.examples robot_h1
|
|
|
|
python -m newton.examples robot_anymal_d
|
python -m newton.examples robot_anymal_c_walk
|
python -m newton.examples robot_policy
|
|
|
|
python -m newton.examples robot_ur10
|
python -m newton.examples robot_panda_hydro
|
python -m newton.examples robot_allegro_hand
|
|
|
|
python -m newton.examples robot_omniwheel
|
python -m newton.examples robot_asroballet
|
|
|
|
|
| Run joint impedance heterogeneous | Run operational space hybrid force/motion |
python -m newton.examples controller_differential_ik
|
|
|
|
python -m newton.examples cable_twist
|
python -m newton.examples cable_y_junction
|
python -m newton.examples cable_bundle_hysteresis
|
|
|
|
python -m newton.examples cable_pile
|
python -m newton.examples cable_cross_slide_table
|
python -m newton.examples cable_plectoneme
|
|
||
python -m newton.examples cable_initial_rest_pose
|
||
|
|
|
python -m newton.examples tendon_pulley
|
python -m newton.examples tendon_pinhole
|
python -m newton.examples tendon_capstan_friction
|
|
|
|
python -m newton.examples tendon_mujoco_switch
|
python -m newton.examples tendon_3d_routing
|
|
|
|
|
python -m newton.examples cloth_bending
|
python -m newton.examples cloth_hanging
|
python -m newton.examples cloth_style3d
|
|
|
|
python -m newton.examples cloth_h1
|
python -m newton.examples cloth_twist
|
python -m newton.examples cloth_franka
|
|
|
|
python -m newton.examples cloth_rollers
|
python -m newton.examples cloth_poker_cards
|
|
|
|
|
python -m newton.examples ik_franka
|
python -m newton.examples ik_h1
|
python -m newton.examples ik_custom
|
|
||
python -m newton.examples ik_cube_stacking
|
||
|
|
|
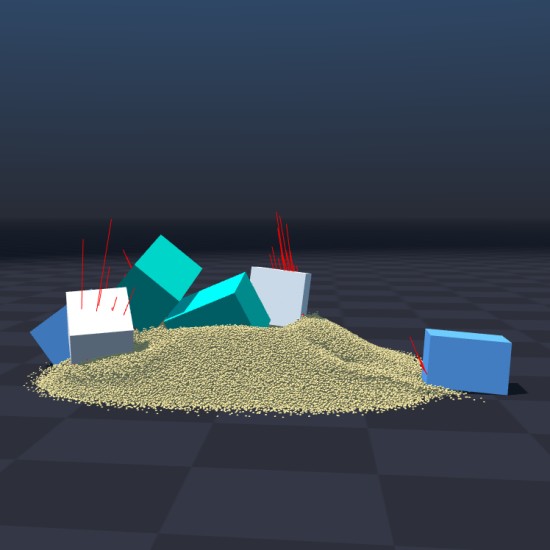
python -m newton.examples mpm_granularpython -m newton.examples mpm_granular --from-usd
|
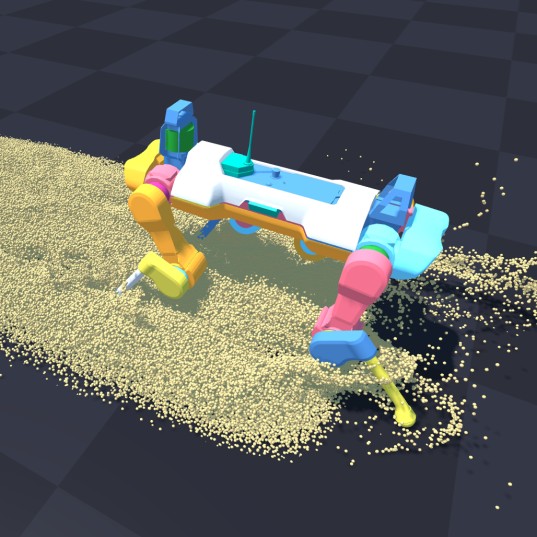
python -m newton.examples mpm_anymal
|
python -m newton.examples mpm_twoway_coupling
|
|
|
|
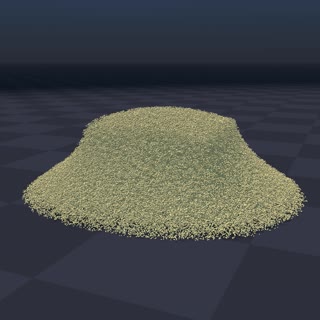
python -m newton.examples mpm_grain_rendering
|
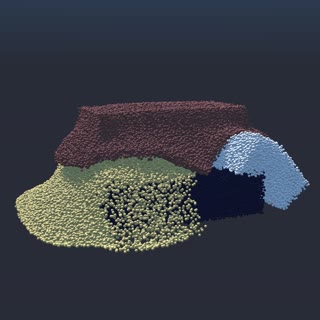
python -m newton.examples mpm_multi_material
|
python -m newton.examples mpm_viscous
|
|
|
|
python -m newton.examples mpm_beam_twist
|
python -m newton.examples mpm_snow_ball
|
python -m newton.examples mpm_water_dam_break
|
|
||
python -m newton.examples mpm_pinch_carry
|
||
|
|
|
python -m newton.examples sensor_contact
|
python -m newton.examples sensor_camera
|
python -m newton.examples sensor_imu
|
|
|
|
python -m newton.examples selection_cartpole
|
python -m newton.examples selection_materials
|
python -m newton.examples selection_articulations
|
|
||
python -m newton.examples selection_multiple
|
||
|
|
|
python -m newton.examples diffsim_ball
|
python -m newton.examples diffsim_cloth
|
python -m newton.examples diffsim_drone
|
|
|
|
python -m newton.examples diffsim_spring_cage
|
python -m newton.examples diffsim_soft_body
|
python -m newton.examples diffsim_bear
|
|
|
|
python -m newton.examples softbody_gift
|
python -m newton.examples softbody_dropping_to_cloth
|
python -m newton.examples rigid_soft_contact
|
|
|
|
python -m newton.examples franka_cable_ik_pick_place
|
Run MuJoCo Franka VBD cable ADMM |
python -m newton.examples vbd_dat_rigid_soft
|
|
|
|
python -m newton.examples nut_bolt_hydro
|
python -m newton.examples nut_bolt_sdf
|
python -m newton.examples brick_stacking
|
|
|
|
python -m newton.examples pyramid
|
python -m newton.examples contacts_rj45_plug
|
python -m newton.examples newton_cradle
|
|
|
|
python -m newton.examples balance_bird
|
python -m newton.examples domino_spiral
|
python -m newton.examples adaptive_collision
|
|
|
|
python -m newton.examples softbody_hanging
|
python -m newton.examples softbody_franka
|
|
|
|
|
python -m newton.examples kamino_basic_dr_testmech
|
python -m newton.examples kamino_basic_fourbar
|
python -m newton.examples kamino_basic_heterogeneous
|
|
|
|
python -m newton.examples kamino_robot_anymal_d
|
python -m newton.examples kamino_robot_dr_legs
|
python -m newton.examples kamino_earworm_flowers
|
|
|
|
python -m newton.examples steel_sleeping
|
python -m newton.examples steel_determinism_arms
|
|
Show command
python -m newton.examples controller_joint_impedance_heterogeneousShow command
python -m newton.examples controller_operational_space_hybrid_force_motionShow command
python -m newton.examples mujoco_franka_vbd_cable_admm_solverAll examples share a common set of command-line options. The most commonly used ones are:
| Argument | Description | Default |
|---|---|---|
--viewer |
Viewer to use: gl, usd, rtx, rerun, viser, or null. |
gl |
--device |
Compute device to use, e.g., cpu, cuda:0. |
None (default Warp device) |
--num-frames |
Total number of frames to simulate. | 100 |
--output-path |
Path to the output USD file (used by the usd viewer). |
output.usd |
For the complete, always-current list of options — plus any arguments a specific example adds — run:
python -m newton.examples <example_name> --help# List available examples
python -m newton.examples --list
# Run with the USD viewer and save to my_output.usd
python -m newton.examples basic_viewer --viewer usd --output-path my_output.usd
# Run on a selected device
python -m newton.examples basic_urdf --device cuda:0
# Combine options
python -m newton.examples basic_viewer --viewer gl --num-frames 500 --device cpuSee PUBLICATIONS.md for research using Newton, inclusion criteria, and instructions for adding your publication.
See CONTRIBUTING.md for ways to contribute and the pull-request process. The governance contribution guidelines cover legal requirements, project roles, and approval authority. Use the development guide for environment setup and development workflows. Code and public API changes must follow the source code guidelines; reviewers may use the suggested review guidelines.
For questions, please consult the Newton documentation first before creating a discussion in the main repository.
By participating in this community, you agree to abide by the Linux Foundation Code of Conduct.
Please see the newton-governance repository for more information about project governance.